Custom Three Phase Vibration Motor Selection: Torque, Speed, and Mounting Options
2026-10-25
When a standard three-phase vibration motor can't meet your application's demands, the real challenge begins: balancing torque, speed, and mounting constraints without compromising reliability. That's where Guangling comes in—offering custom solutions that go beyond off-the-shelf limits. In this post, we'll break down the key selection criteria so you can specify the right motor without guesswork.
Torque Profiles That Match Your Exact Shaker Load
A torque curve that ignores your shaker's real load is just a guess with extra steps. When the bed is heavy with wet fines, the motor has to push through a different resistance than when it's running dry and light. So we build profiles from the load signature itself—sampling torque demand across the full stroke and letting the drive adapt to what the material is actually doing at that moment.
What comes out of that process feels almost intuitive: the machine accelerates without lurching, holds speed through the thick parts of the cycle, and backs off before the frame takes a hit. Change the feed or switch screen media, and the profile shifts with it. You don't retune. You don't override. The load sets the rhythm, and the torque follows.
Speed Sweet Spots for Quiet, Efficient Vibration
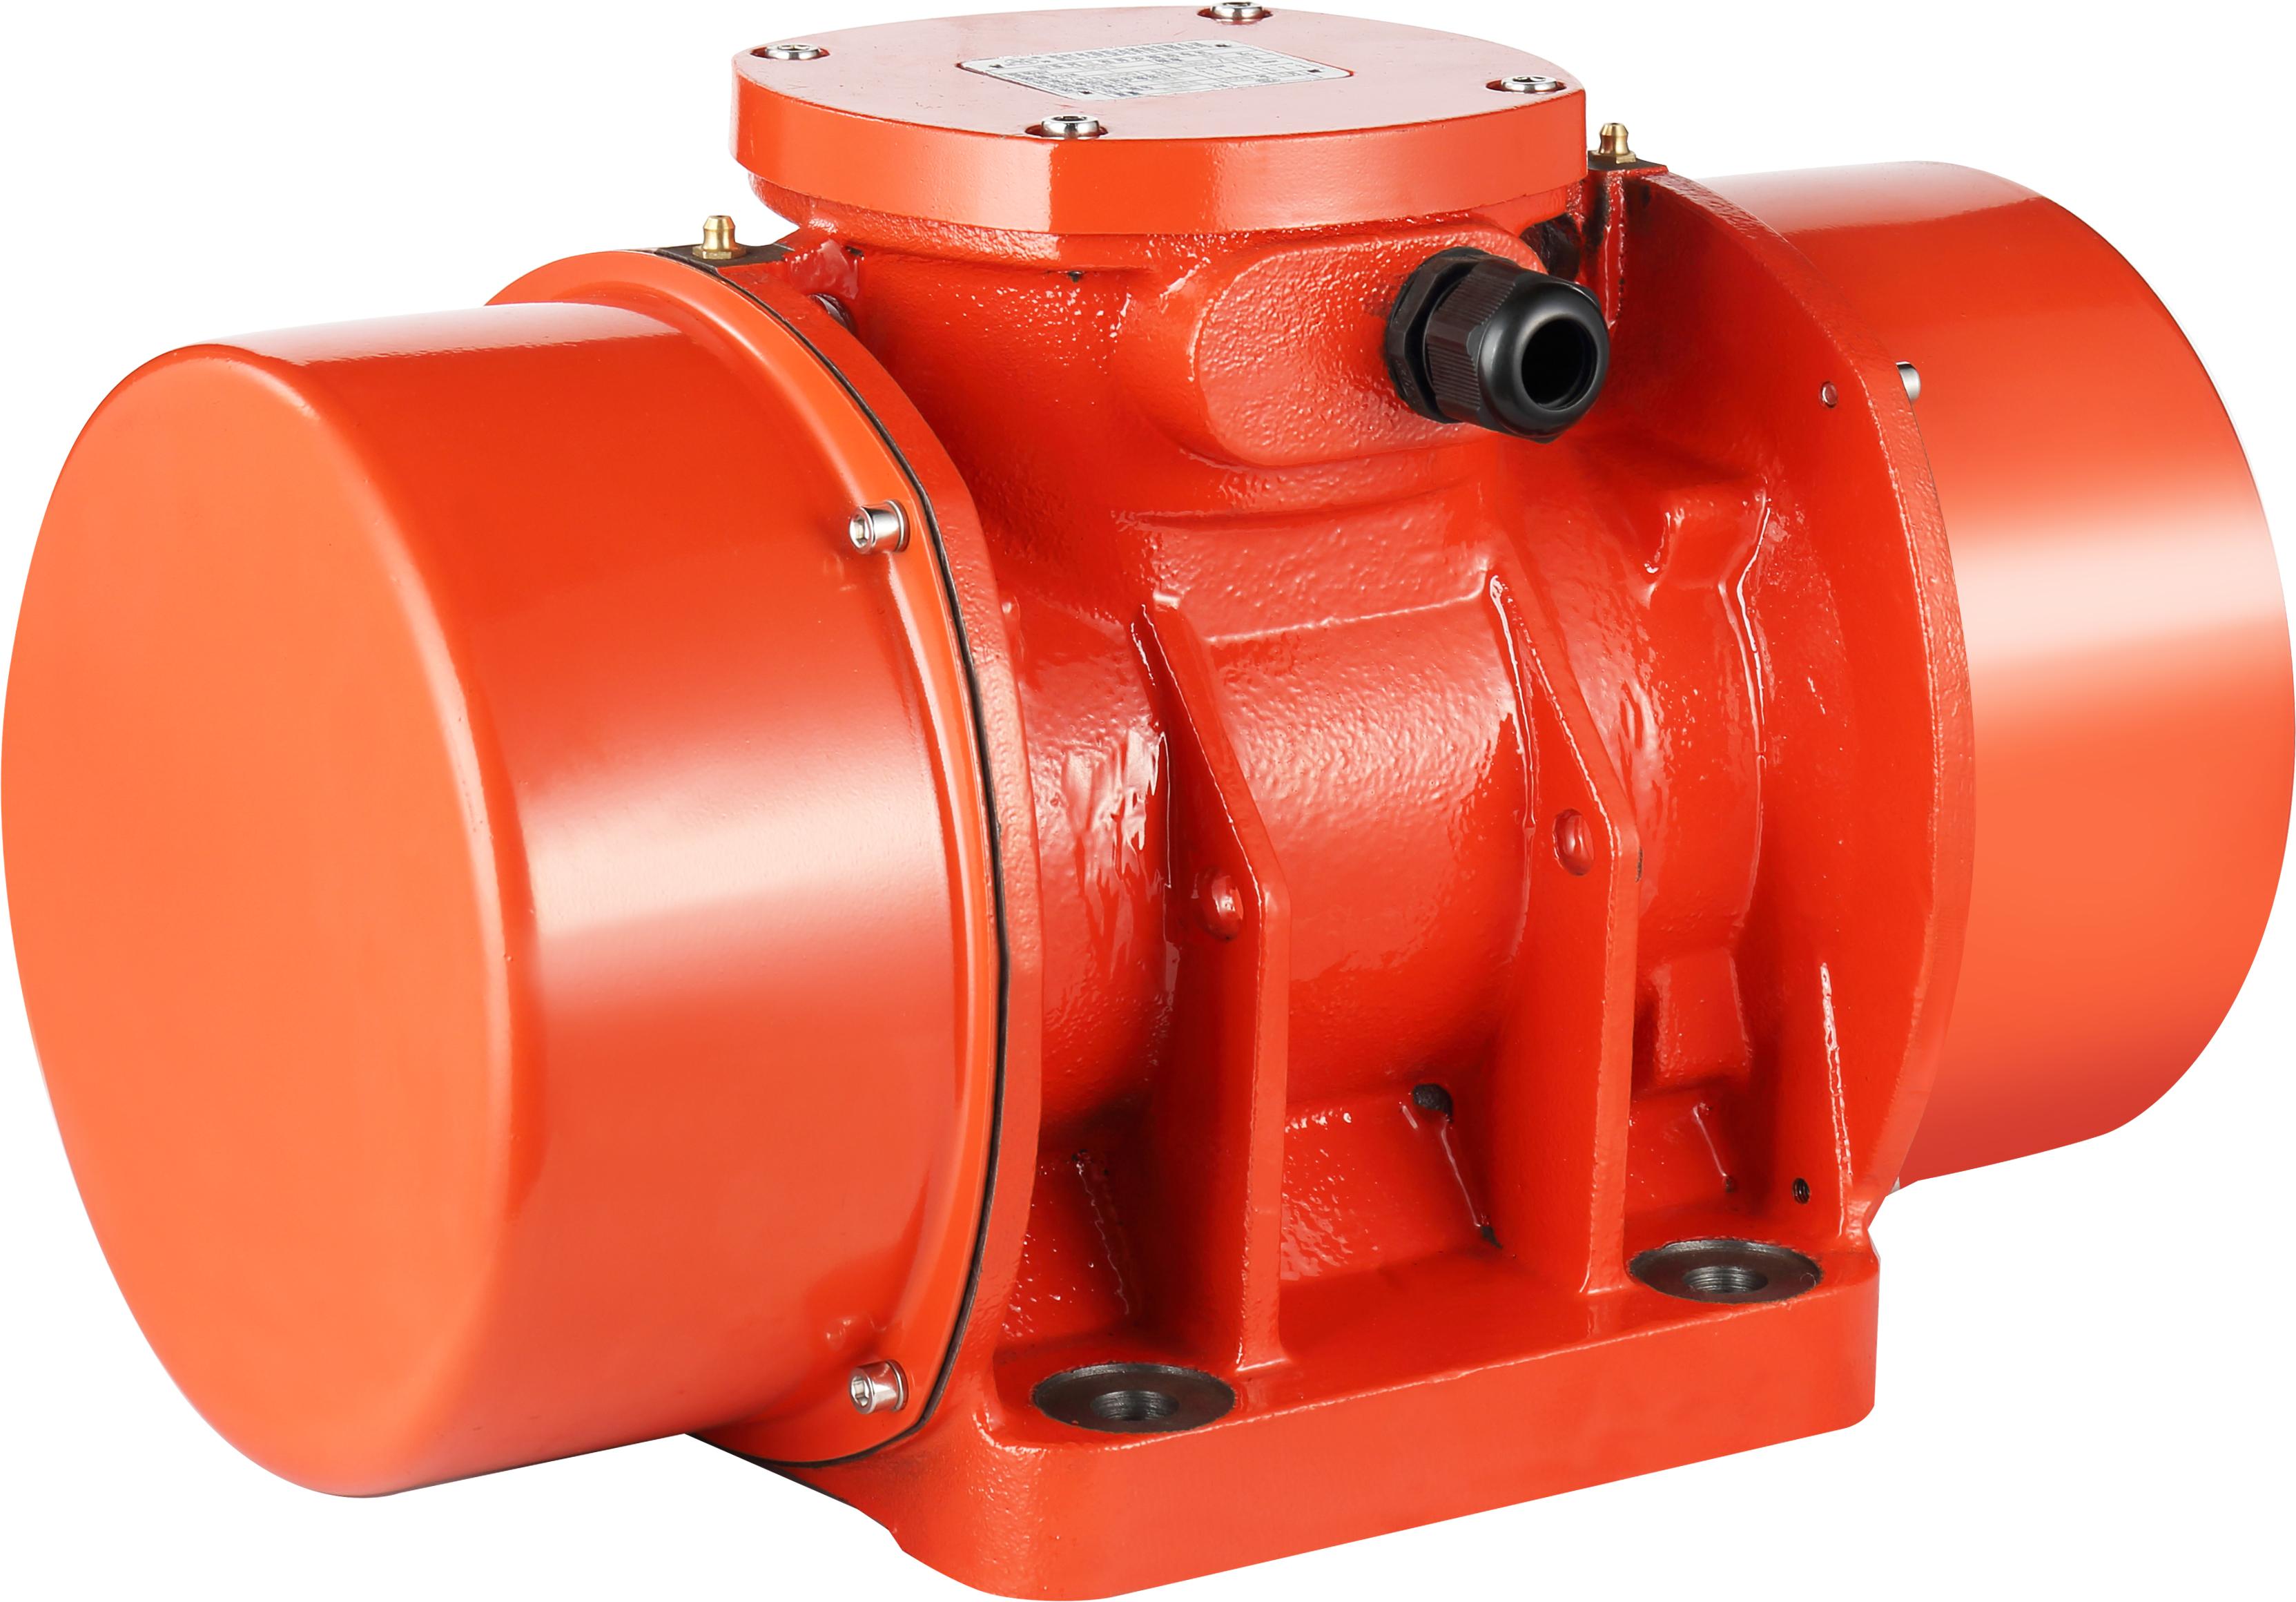
Finding the right rotational speed isn't just about hitting peak power—it's about discovering where the motor and structure stop fighting each other. Many systems produce excessive noise and wasted energy because they operate slightly above or below their natural resonance points. By mapping vibration amplitude against frequency, you can identify narrow bands where the mechanical impedance drops sharply. These are the speed sweet spots: settings that deliver the intended motion with minimal audible hum and thermal buildup.
One practical approach is to start with a baseline sweep across the expected operating range, recording acceleration and sound pressure level at each step. Don't just look for the lowest vibration overall—that might correspond to a speed too slow for the task. Instead, look for local minima where the vibration drops significantly compared to adjacent speeds while still meeting your throughput requirement. In many brushless DC and stepper applications, this sweet spot often sits between 60% and 80% of the rated maximum speed, but the exact value depends on bearing stiffness, rotor imbalance, and mounting compliance.
Once identified, lock that speed into the controller rather than allowing broad variable-speed operation. If the load varies, use a narrow hysteresis band around the sweet spot to avoid drifting back into noisy regions. For systems that must run across a range of speeds, consider adding tuned mass dampers or adjusting the coupling stiffness to shift the resonance away from the critical operating band. The result is a quieter, cooler-running device that uses less energy for the same mechanical output—without resorting to heavier enclosures or aggressive filtering.
Mounting Options Beyond Standard Foot and Flange
When a standard foot-mounted or flange-mounted arrangement can't satisfy space, alignment, or load-path requirements, a few less obvious possibilities often come into play. A hollow-shaft design paired with a torque arm, for instance, lets the driven shaft carry the unit's weight while the torque arm reacts against a fixed anchor. This eliminates the need for a machined mounting base and gives a surprising amount of flexibility in vertical or inclined installations. Similarly, a footless housing with an oversized output bearing can be bolted directly to a machine frame through a custom pilot, reducing stack-up tolerances and freeing up floor space.
Another route that gets overlooked is the use of multi-position flanges or split mounting brackets. These allow the same gear unit to be rotated in 90-degree increments without remachining, which is useful when oil fill, breather, or drain locations must line up with the final orientation. For applications with high overhung load or continuous vibration, a rigid wall or ceiling plate can be combined with a reinforced housing adapter, distributing reaction forces across a broader area than a conventional foot ever could. In many cases, the best answer isn't a single exotic mount, but a simple modification like relocating the breather, adding a drip cover for vertical shaft-down operation, or welding a small reaction bracket to an existing structure.
Customizing Torque and Speed for Unusual Duty Cycles
Every so often, a machine comes along that doesn't fit the standard S1 continuous duty curve. Think of a press that slams every forty seconds, a winch that hauls for two minutes then rests for ten, or a spindle that sees full load only during a deep roughing pass. In these cases, picking a motor based on nameplate continuous torque is a fast way to end up with an oversized frame or an overheating rotor. Instead, you start by mapping out the actual load profile: how much torque is needed, for how long, and how much cooling happens between the bursts. That profile becomes the basis for choosing a drive that can deliver short-term overload capacity without tripping or cooking the windings.
Once the duty cycle is clear, you can adjust speed and torque limits to match the real work. A common trick is to run the motor above its continuous rated speed during light-load portions, then let it sag back under heavy torque when the load demands it. Field weakening in AC induction motors or flux reduction in permanent magnet servos gives you that extra rpm range without needing a bigger frame. At the same time, the drive's current limit can be set high enough to allow 150% or 200% torque for a few seconds, but low enough that the thermal model doesn't false trip. Tuning these limits is less about guesswork and more about running short test cycles and watching temperature rise.
Finally, unusual duty cycles often reward a bit of creative cooling and mechanical leverage. A small blower aimed at the motor end bell can buy back a surprising amount of overload margin. Changing pulley ratios or gearbox stages shifts the operating point so the motor spends more time in its efficient zone. In some setups, adding a flywheel smooths out the spikes so the drive sees a lower peak torque and the motor stays cooler. The goal isn't to force a standard motor into a weird job; it's to reshape the system's torque-speed envelope so the machine does exactly what the process needs without wasting energy or tripping faults.
Bracket, Base, or Face Mount: What Fits Your Frame
Choosing between a bracket, base, or face mount usually comes down to how your frame distributes load and where you have clearance. Brackets work well when the frame has vertical or horizontal members you can clamp or bolt to, and they give you some flexibility for later adjustments. If you're dealing with a welded tube frame or an extrusion profile, a bracket mount often avoids drilling into load-bearing faces.
Base mounts shine when the frame sits on a flat surface and you need the equipment weight to travel straight down into the floor. This is common for pumps, motors, or heavy enclosures. The trade-off is footprint: a base plate extends outward, so tight aisles or machine guarding can become a problem. Face mounts, by contrast, tuck the component against a panel or sidewall, which is great for cabinets or narrow frames. But you'll want to check the panel thickness and stiffness before hanging anything heavy.
A useful rule of thumb is to identify where the reaction forces will concentrate. If the frame already has gussets or cross-bracing, a face mount may amplify vibration. If the base has leveling feet, a base mount can integrate cleanly. Don't assume one style is universally better; mixed mounting is often the most practical answer on retrofits.
From Torque Spec to Installed Motor: A No-Nonsense Path
Torque specs live on a page; the motor sits on a pallet. Bridging that gap starts with reading the fastener list against the actual hardware in your hand. Note thread condition, bolt grade, and whether the flange faces are clean. A dry specification on a rusty stud will never match the printed number, so chase threads and apply the exact lubricant or locking compound the manufacturer calls for—nothing else.
Mounting is a sequence, not a race. Bring every bolt to roughly half the target in a star pattern so the motor settles flat against its mating surface. Then walk torque up in two or three steps, checking that the housing doesn't shift or bind. This is where a cheap beam wrench beats a fancy digital one if it hasn't been calibrated this year.
After the final pull, resist the urge to add a little extra "for safety." Mark each fastener, rotate the shaft by hand, and recheck a cold torque after a short run-in if the manual requires it. Installed means more than bolted down—it means the numbers on the sheet now match the metal.
FAQ
Start with the eccentric weight moment and the operating speed. The centrifugal force is m·e·ω², where m is the eccentric mass, e is the offset distance, and ω is the angular velocity. Torque mainly needs to overcome bearing friction and start-up inertia, so pick a motor whose locked-rotor torque is at least 2–2.5 times the running torque. For most circular separators under 2m diameter, a 0.5–2.2 kW motor with 30–60 Nm of starting torque works well.
At 60 Hz, a 2-pole motor runs near 3600 rpm to deliver about 60 Hz vibration, a 4-pole near 1800 rpm gives 30 Hz, and a 6-pole near 1200 rpm gives 20 Hz. Lower pole counts produce higher frequencies that suit fine material screening, while higher pole counts are better for conveying or compacting because the longer stroke at lower frequency moves material without fluidizing it.
Vertical side-wall mounting is possible, but the motor must have angular-contact or spherical roller bearings rated for combined radial and axial loads. A standard deep-groove ball bearing setup will fail quickly because the rotor's weight and the vibration forces create constant axial thrust. Also check that the terminal box is sealed against fine dust ingress from above.
Foot-mounted motors transfer vibration through the base and need a rigid, flat mounting plate; any air gap under the foot causes uneven stress and hotspots. Flange-mounted motors bolt directly to the equipment face, which improves heat sink contact and reduces resonance because the motor mass is closer to the driven surface. For continuous duty above 80°C ambient, flange mounting usually runs cooler by 5–10°C.
Use a VFD with sensorless vector control and enable voltage boost at low speed. The motor's cooling fan also slows down, so add an independent blower if you plan to run below 30 Hz for more than a few minutes. Keep the eccentric weights at their original setting and verify the drive's carrier frequency is at least 8 kHz to reduce audible whine without derating the motor too much.
Yes, most manufacturers can machine a custom flange or adapter plate with the legacy hole circle. Provide the exact bolt circle diameter, number of holes, and hole size. Keep the adapter thickness between 15–25 mm so it adds stiffness without creating a new resonance point. Also request high-tensile class 12.9 bolts and Nord-Lock washers to prevent loosening.
Specify an IP66 enclosure, a labyrinth seal on the shaft, and greased-for-life bearings with C3 internal clearance. The stator should be vacuum-pressure impregnated with epoxy resin. Insist on a reinforced terminal box with a cable gland rated for continuous vibration. A thermal protection switch embedded in the windings is a must to shut down before insulation breakdown.
Conclusion
Selecting a custom three phase vibration motor isn't about grabbing a catalog number and hoping for the best. It starts with torque profiles that actually mirror your shaker's load—whether it's a gentle sift on fine powders or a brutal knock on heavy castings. The right motor doesn't just hit a peak torque number; it delivers consistent force through the entire stroke, avoiding dead spots that cause uneven material flow. Speed is equally critical, and the sweet spot often sits far from the nameplate's 50 or 60 Hz. Running slightly off resonance can slash noise and energy waste while boosting throughput. For unusual duty cycles—frequent reversals, hammering starts, or long dwell times—customizing both torque and speed curves together makes the difference between a motor that survives a month and one that runs for years without a hiccup.
Mounting is where many standard selections fall apart. Foot and flange mounts are fine for bench-top testers, but real installations often need a bracket welded to a hopper wall, a face mount tucked inside a compact housing, or a base plate that doubles as a structural brace. Matching the mount to the frame's vibration mode prevents cracked castings and loosened bolts down the line. The path from torque spec to installed motor should be direct: you define the load, the duty cycle, and the physical envelope, then the motor builder tailors the winding, rotor inertia, and mounting interface to fit. No guessing, no universal "close enough" compromise. That's how you get a three phase vibration motor that feels less like a bought part and more like a designed-in component of your process.
Contact Us
Contact Person: ZHUO
Email: [email protected]
Tel/WhatsApp: 86-576-86320988
Website: https://www.cnguangling.com